数据截至Data as of
2026-10-21T05:07Z
RGS-N132D handbook
What is the author's name?
请输入页面作者的名字。
Incorrect / 不正确
项目对读者的名字是 RGS-N132D(代码与文件夹名 S2Fitting,PI 于 2026-10-20 决定,D32):一条可重复的 XMM-Newton RGS 空间到光谱前向拟合管线。SAS(Science Analysis System)负责仪器校准、事件、抽谱区域、光谱与响应矩阵;Python 负责配置、编排、验证、Sherpa 模型与结果发布。当前科学目标(PI 于 2026-10-19/20 设定,PI 第 29 号决定及其第 33、34 号修订)是:用一条合并窄带(核心 14.69-23.45 Å,先做纯氧阶段 18.20-23.45 Å)同时建模 O VII、O VIII、N VII 与 Fe L,得到发射气体的空间分布与速度分布。本页是工作台:这个项目是什么、现在走到哪里、什么还没解决、下一步做什么。The project's reader-facing name is RGS-N132D (code and folder name S2Fitting, decided by the PI on 2026-10-20, D32): a reproducible XMM-Newton RGS spatial-to-spectral forward-fitting pipeline. SAS owns instrument calibration, events, extraction regions, spectra and response matrices; Python owns configuration, orchestration, validation, Sherpa model composition and result publication. The current science goal (set by the PI on 2026-10-19/20, PI decision 29 as revised by decisions 33 and 34) is to model O VII, O VIII, N VII and Fe L together in one combined narrow band (core 14.69-23.45 Angstrom, an oxygen-only stage at 18.20-23.45 Angstrom first) and obtain the emitting gas's spatial and velocity distributions. This page is the workbench: what this is, where it stands, what is unsolved, and what comes next.
2026-10-21(UTC,进行中) —— 成果:Suzuki 等人 (2020) 全文深读完成(LIT4 双 agent,未复核)——该文已做积分三联诊断、三温度 NEI 与按 roll/能量分段的 Chandra 轮廓响应平滑,因此“首次 RGS 谱/扩展源改正/f-r 测量”都不是本项目的创新点;唯一明确的空间新结果是 O VII 禁线天空偏移(约 3.2-3.6″ 北向),而 \(\sigma_v \approx 500\) km/s 与 Suzuki 的 438/445 km/s 属同一量级而非新发现。PI 第 36 号决定:今后每条 headline 必须带“对比 Suzuki 2020”的创新性标签。GOF 共因红队(红队第 32 号,未复核):泊松模拟本身正确;18 个廉价自由参数(归一 + 背景尺度)只买到 \(\Delta C = -17.4\) / \(-49.7\),超出仍为 \(z = +7.13\) / \(+10.16\);O VIII 失配集中在 Ly-alpha 翼(占 45.1 % 的 \(\chi^2\))加蓝边超出,O VII 失配平滑弥散。分阶段 roll 拟合第 1 阶段(第 36 号实验,未复核):三观测 L 模型过新收敛门,\(v_0 = 34.5\) km/s、\(|g| = 121.7\) km/s/′、\(\sigma_v = 396.4\) km/s;L2ion 未过门。问题:机器长期饱和(CPU 97-99.9 %);本 agent 上一会话因“响应过大”中断,本会话为全新接手。待 PI:是否把 LIT4 的某条候选 headline 提升为论文/幻灯片主结论。2026-10-21 (UTC, in progress) — Results: the full deep read of Suzuki et al. (2020) is complete (LIT4 dual agents, unreviewed) — that paper already did integrated triplet diagnostics, a three-temperature NEI model and Chandra-profile response smoothing by roll angle and energy interval, so "first RGS spectrum / extended-source correction / f-versus-r measurement" are not this project's novelty; the one clearly new spatial result is the O VII forbidden-line sky offset (about 3.2-3.6 arcsec north), while \(\sigma_v \approx 500\) km/s is the same scale as Suzuki's 438/445 km/s rather than a new finding. PI decision 36: every headline must from now on carry a "versus Suzuki 2020" novelty label. The GOF common-cause red team (red team 32, unreviewed): the Poisson simulation is correct; 18 cheap free parameters (normalisations plus background scales) buy only \(\Delta C = -17.4\) / \(-49.7\), leaving the excess at \(z = +7.13\) / \(+10.16\); O VIII's misfit concentrates in the Ly-alpha wings (45.1 % of the \(\chi^2\)) plus a blue-edge excess, while O VII's is smooth and distributed. Stage 1 of the staged roll-angle fit (experiment 36, unreviewed): the three-observation L model passes the new convergence gate with \(v_0 = 34.5\) km/s, \(|g| = 121.7\) km/s per arcmin and \(\sigma_v = 396.4\) km/s; L2ion does not pass. Problems: the machine has been saturated (CPU 97-99.9 %); this agent's previous session died ("response too large") and this is a fresh session taking over. For the PI: whether to promote one of LIT4's candidate headlines to the paper's or the deck's central claim.
更早的天(2026-10-20:14 观测联合拟合第一批结果与 GOF 共因排除;2026-10-19:PI 第 29 号决定设定目标;handbook 首建与评审 1 返工;11 个新观测约简完成;NIM 代理停摆 3 小时)见组会记录。Earlier days (2026-10-20: the 14-observation joint fit's first batch and the GOF common-cause exclusions; 2026-10-19: the goal set by PI decision 29; the handbook's first build and review-1 rework; 11 new observations reduced; the NIM proxy down for 3 hours) are in the group-meeting record.
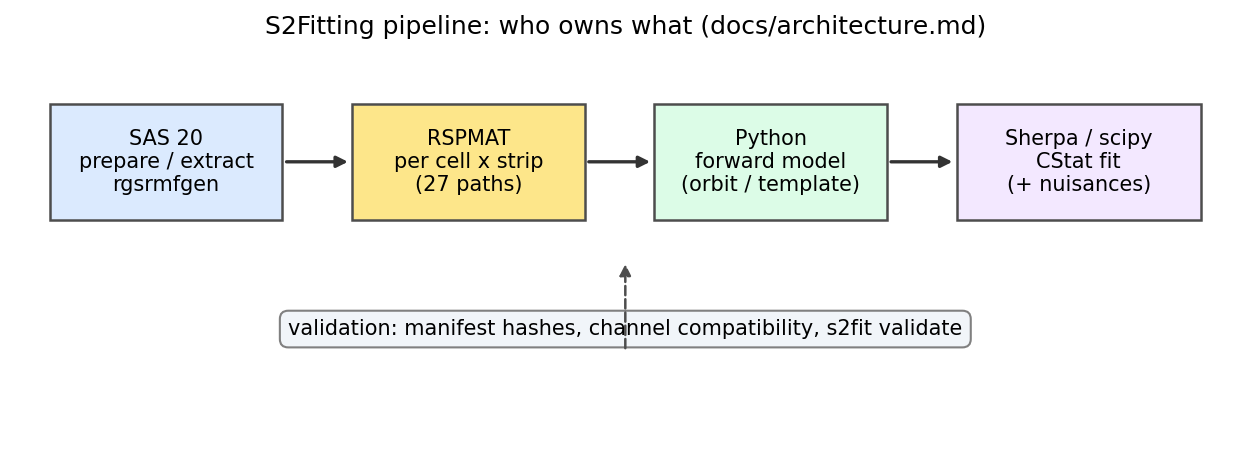
来源:docs/architecture.md(数据流与所有权边界)、cognition-os/experiments/E018_real-data-readiness.md(前向模型与讨厌参数组)。Source: docs/architecture.md (data flow and ownership boundaries), cognition-os/experiments/E018_real-data-readiness.md (forward model and nuisance set).
| 目标Objective | 状态Status | 当前最佳数值Best number now | 来源Source | 趋势Trend |
|---|---|---|---|---|
| 合并氧带(O VII+O VIII+N VII+Fe L)的速度场Velocity field of the combined oxygen band (O VII + O VIII + N VII + Fe L) | ProvisionalProvisional | 14 obs 第一批(未复核,PI 第 35 号决定后仅作参考): O VII \(v_0 = 41.6 \pm 9.1\) km/s \(|g| = 137.4 \pm 11.3\) km/s/′ \(\sigma_v = 466.7 \pm 10.6\) km/s O VIII \(|g| = 0\)(边界)、\(\sigma_v = 497.8 \pm 6.6\) km/s 分阶段三观测(第 36 号实验,未复核): \(v_0 = 34.5\)、\(|g| = 121.7\) km/s/′ \(\psi = -38.0^\circ\)、\(\sigma_v = 396.4\) km/s14-obs first batch (unreviewed, reference-only after PI decision 35): O VII \(v_0 = 41.6 \pm 9.1\) km/s \(|g| = 137.4 \pm 11.3\) km/s/arcmin \(\sigma_v = 466.7 \pm 10.6\) km/s O VIII \(|g| = 0\) (bound), \(\sigma_v = 497.8 \pm 6.6\) km/s staged three-observation (experiment 36, unreviewed): \(v_0 = 34.5\), \(|g| = 121.7\) km/s/arcmin \(\psi = -38.0^\circ\), \(\sigma_v = 396.4\) km/s |
E033 报告report(未复核,仅参考)(unreviewed, reference-only) E036 报告report(未复核)(unreviewed) |
\(\sigma_v\) 仍在 400-500 km/s;分阶段拟合取代 14 观测一步跳\(\sigma_v\) still 400-500 km/s; the staged fit replaces the 14-observation jump |
| \(\sigma_v\) 是内部弥散还是整体分裂?Is \(\sigma_v\) internal dispersion or a bulk split? | ProvisionalProvisional | \(\Delta\mathit{Cstat} = -151.7\)(7 参数;红队第 29 号 复算) 分裂法线离 O1/O2 色散法线 \(1.4\)-\(2.5^\circ\)\(\Delta\mathit{Cstat} = -151.7\) (7 parameters; red team 29 replay) split normal within \(1.4\)-\(2.5^\circ\) of the O1/O2 dispersion normals |
I029, RT29(红队第 29 号 未复核)(red team 29 unreviewed) |
不是泊松涨落,但与色散轴简并,需新 roll 角not a Poisson fluke, but degenerate with the dispersion axes; needs new roll angles |
| 合并带的边与谱线清单(奥卡姆)The combined band's edges and Occam line list | ProvisionalProvisional | 核心 14.69-23.45 Å;纯氧 18.20-23.45 Å;8 个混合成分,每个 \(\Delta\mathit{BIC} > 0\) 且 Asimov 可恢复core 14.69-23.45 Angstrom; oxygen-only 18.20-23.45 Angstrom; 8 blends, each \(\Delta\mathit{BIC} > 0\) and Asimov-recoverable | E032 报告report(未复核)(unreviewed) |
已定稿,待复核fixed, awaiting review |
| f 线天空偏移的形态:刚性平移还是比值梯度?The f-line sky offset's morphology: rigid shift or ratio gradient? | 改读re-read | 梯度 \(\Delta C = -75.33\) 优于平移 \(-53.45\)(同 2 参数);给定梯度后平移只剩 \(\Delta C = -3.67\)(吸收 93 %)the gradient's \(\Delta C = -75.33\) beats the shift's \(-53.45\) (both 2 parameters); given the gradient, the shift retains only \(\Delta C = -3.67\) (93 % absorbed) | RT30 报告report(未复核)(unreviewed) |
“f/r 分布不同”高置信;“刚性平移”不再是唯一读法high confidence the f/r distributions differ; a rigid shift is no longer the unique reading |
| 可用数据Usable data | 就绪ready | 14 obs(3 + 11);28 个合并带响应包(875 再生 + 105 复用),4443 文件哈希通过;26/28 单元可用14 obs (3 + 11); 28 combined-band response packs (875 regenerated + 105 reused), 4443 files hash-verified; 26 of 28 units usable | E024、E034 |
已就绪(第 34 号实验 完成)ready (experiment 34 complete) |
| 仪器系统误差Instrument systematics | 基本关闭largely closed | \(\le 0.1\) SD(典型) \(w \approx -3\,\%\) 未解释\(\le 0.1\) SD (typical) \(w \approx -3\,\%\) unexplained |
I028、I025 |
讨厌参数组有效the nuisance set works |
| 结果相对 Suzuki 2020 的创新性The results' novelty relative to Suzuki 2020 | 已建立规则rule set | “新”的只有:O VII 禁线天空偏移(约 3.2-3.6″ 北向);O VII 空间速度梯度(方向不稳健) “同一量级”的:\(\sigma_v \approx 500\) km/s(Suzuki 438/445);全球 f/r;线清单;用 Chandra 轮廓改响应 来源:LIT4 双报告 §4/§6(PI 第 36 号决定)"New" only: the O VII forbidden-line sky offset (about 3.2-3.6 arcsec north); a spatially resolved O VII velocity gradient (direction not robust) "Same scale": \(\sigma_v \approx 500\) km/s (Suzuki 438/445); the global f/r; the line inventory; using Chandra-profile response convolution Source: the two LIT4 reports, sections 4 and 6 (PI decision 36) |
LIT4 报告reports(未复核)(unreviewed) |
每条 headline 今后必须带创新性标签every headline must now carry a novelty label |
来源:cognition-os/02_CURRENT_QUESTION.md(子问题表)、cognition-os/03_TRUST_TABLE.md(每条结论的当前信任标签)、cognition-os/04_DECISION_LOG.md(D29,PI 短期目标)。SD 指 Fisher 标准误(standard deviation)。Source: cognition-os/02_CURRENT_QUESTION.md (sub-question table), cognition-os/03_TRUST_TABLE.md (the current trust label of each claim), cognition-os/04_DECISION_LOG.md (D29, the PI's short-term goal). SD means Fisher standard deviation.
| 问题Problem | 为何重要Why it matters | 最佳假设Best hypothesis | 下一个检验Next test | 状态Status |
|---|---|---|---|---|
| 两个窄带都不通过泊松拟合优度检验(O VII z \(\approx +8\)、O VIII \(\approx +11\))Both narrow bands fail the Poisson goodness-of-fit test (O VII z \(\approx +8\), O VIII \(\approx +11\)) | 所有速度数值都以速度模型为条件;这是当前主要限制Every velocity number is conditional on the velocity model; this is the current main limitation | 已排除:多余谱线、背景、LSF 宽度、Ly-alpha 形状(第 28 号实验/第 29 号实验)、粗模板失配(第 31 号实验 分块到 4x4 仍 \(z > +3\))、非高斯速度轮廓与 LSF 翼(第 35 号实验 中只有“高斯+宽高斯”同时改善两带,\(\sigma_2 \approx 750\)-920 km/s,占 \(\approx 0.36\),但 GOF 仍不合格)、逐观测 x 条带归一与背景尺度(红队第 32 号:18 个参数只买 \(\Delta C = -17.4\) / \(-49.7\),\(z\) 仍 \(+7.13\) / \(+10.16\))。剩余失配是平滑、跨带、带边加权的超出,加(仅 O VIII)Ly-alpha 宽度缺陷Ruled out: extra lines, background, LSF width, Ly-alpha shape (experiment 28/experiment 29); coarse template mismatch (experiment 31, still \(z > +3\) up to 4x4 blocks); non-Gaussian velocity profiles and LSF wings (in experiment 35 only Gaussian-plus-broad-Gaussian improves both bands, \(\sigma_2 \approx 750\)-920 km/s at fraction \(\approx 0.36\), but the GOF still fails); per-observation x strip normalisations and background scales (red team 32: 18 parameters buy only \(\Delta C = -17.4\) / \(-49.7\), leaving \(z\) at \(+7.13\) / \(+10.16\)). What remains is a smooth, band-wide, band-edge-weighted excess plus (O VIII only) a Ly-alpha width defect | 逐观测背景光滑形状自由度(第 37 号实验,在 lang2 上,进行中);若仍不合格则问题在源模型(连续谱模板或线宽)a per-observation smooth background shape freedom (experiment 37, on lang2, in progress); if it still fails, the defect is in the source model (continuum template or line width) | 在跑running |
| f 线偏移是刚性平移还是 f/r 比值梯度Is the f-line offset a rigid shift or an f/r ratio gradient | 它决定梯度读数的系统误差(0.3-0.6 SD)与物理图像(位置不同 vs 比例不同)It sets the gradient reading's systematic (0.3-0.6 SD) and the physical picture (displaced gas versus a different ratio) | 22.19 Å 混合线被拒(红队第 30 号:0 % 吸收,几何反号);比值梯度拟合更好并吸收 93 % 的平移 \(\Delta C\)the 22.19 Angstrom blend is rejected (red team 30: 0 % absorbed, geometry sign-flipped); the ratio gradient fits better and absorbs 93 % of the shift's \(\Delta C\) | 14 观测堆叠上同时放开两种形态(待 PI)free both morphologies on the 14-observation stack (for the PI) | 待 PI 决定for the PI |
| 三观测双成分分裂与色散轴简并The three-observation two-component split is degenerate with the dispersion axes | 分裂增益 \(\Delta\mathit{Cstat} = -151.7\) 不是泊松涨落,但 O1/O2 色散法线只差 \(3.9^\circ\),分裂法线落在其 \(1.4\)-\(2.5^\circ\) 内the split's \(\Delta\mathit{Cstat} = -151.7\) is not a Poisson fluke, but the O1/O2 dispersion normals differ by only \(3.9^\circ\) and the split normal lies within \(1.4\)-\(2.5^\circ\) of them | 天空结构 vs 锁轴仪器效应当前不可分(红队第 29 号)sky structure versus an axis-locked instrumental effect cannot currently be separated (red team 29) | 分阶段加观测(第 36 号实验):S3 三观测 L 已过门,逐级加 roll 角到 14(S4-S10 待跑,L2ion 未收敛)the staged observation additions (experiment 36): S3's three-observation L passes the gate, roll angles are added stepwise to 14 (S4-S10 pending, L2ion unconverged) | 在跑running |
| 交叉色散尺度 \(w \approx -3\,\%\) 无法用任何已测响应误差解释The cross-dispersion scale \(w\) of about \(-3\,\%\) is explained by no measured response error | \(w\) 与模板宽度简并,直接影响 \(\sigma_v\) 的物理读法\(w\) is degenerate with the template width, which directly affects the physical reading of \(\sigma_v\) | 条带边 \(0.5′\) 内的接受度误差,或模板底座A near-edge acceptance error within \(0.5′\) of the strip edge, or a template pedestal | 合并带拟合中继续带着 \(w\) 自由keep \(w\) free in the combined-band fits | 开着open |
| 分阶段拟合的收敛门与双离子模型The staged fit's convergence gate and the two-ion model | dispatcher 更正 1 把“优化器状态”换成“起点一致 + 有限差分”门后,L 过门、L2ion(双离子)8 个起点只有 2 个一致仍不过——两离子是否该分开拟合尚无定论after dispatcher correction 1 replaced the "optimizer status" gate with "start agreement plus finite difference", L passes but L2ion (two-ion) still fails with only 2 of 8 starts agreeing — whether the two ions should be fitted separately is undecided | 按更正 2:一个模型失败不停整个 job,L2ion 记为未收敛,继续 S4-S10per correction 2: one model's failure does not stop the job, L2ion is recorded as unconverged, and S4-S10 continue | 继续 S4-S10 阶段(每级过门后加下一个 roll 角)continue stages S4-S10 (add the next roll angle once each stage passes the gate) | 未复核unreviewed |
来源:cognition-os/02_CURRENT_QUESTION.md(第 16-23 行)、cognition-os/08_RUNNING.md(在飞的 第 18c 号实验/第 20 号实验/第 21 号实验/RT22/RT23)、cognition-os/REDTEAM_QUEUE.md(RT22、RT23 行)、cognition-os/insights/I029_n132d-ovii-velocity-stage1.md(模型不足与下一步)。Source: cognition-os/02_CURRENT_QUESTION.md (lines 16-23), cognition-os/08_RUNNING.md (the in-flight experiment 18c/experiment 20/experiment 21/RT22/RT23), cognition-os/REDTEAM_QUEUE.md (the RT22 and RT23 rows), cognition-os/insights/I029_n132d-ovii-velocity-stage1.md (model inadequacy and next steps).
.agent/jobs/2026-10-20-e036-staged-rolls-lang2/REPORT.luna.md;方法:按 PI 第 35 号决定在 lang2 上跑;成功:每级过门且参数漂移有解释;失败:记录未收敛并回退上一级;预计 2-3 天。先读:该 job 的 BRIEF.md 与两条 CORRECTION_*.md。Continue experiment 36's staged fit (S4-S10): add the next roll-angle observation once each stage passes the convergence gate; record L2ion's non-convergence openly per dispatcher correction 2. Goal: the stability of \(\sigma_v\) and the gradient with observation count; input .agent/jobs/2026-10-20-e036-staged-rolls-lang2/REPORT.luna.md; method: run on lang2 per PI decision 35; success: each stage passes the gate and parameter drifts are explained; failure: record the non-convergence and fall back one stage; about 2-3 days. Read first: that job's BRIEF.md and the two CORRECTION_*.md files..agent/jobs/2026-10-21-e037-background-shape/。Once experiment 37 (background shape freedom) reports back, triage its GOF conclusion; if \(z < +3\) is reached, "background shape" is confirmed as the GOF common cause, otherwise the smooth band-edge excess is attributed to the source model (continuum template or line width). Input: .agent/jobs/2026-10-21-e037-background-shape/.来源:cognition-os/08_RUNNING.md 第 5、7 节(待派任务与 CoPI 建议)与 cognition-os/02_CURRENT_QUESTION.md(下一步行动)。第 3 条待 PI 决定;第 5 条是 CoPI 的建议方向。Source: cognition-os/08_RUNNING.md sections 5 and 7 (ready-to-dispatch tasks and CoPI proposals) and cognition-os/02_CURRENT_QUESTION.md (next concrete actions). Item 3 awaits the PI; item 5 is a CoPI proposal.
本次更新(2026-10-21,刷新 1 续)What's new (2026-10-21, refresh 1 continued)
刷新 1 的前半(更名 RGS-N132D、组会页首建、2026-10-20 各行)见本页 2026-10-20 的更新条目与 .agent/jobs/2026-10-19-handbook-build/。未复核的任务一律标“未复核”,分诊后以信任表为准。For the first half of refresh 1 (the RGS-N132D rename, the group-meetings page, the 2026-10-20 rows) see this page's 2026-10-20 update entry and .agent/jobs/2026-10-19-handbook-build/. Anything unreviewed is labelled as such; after triage the trust table governs.